Tennis Ball Following Robot
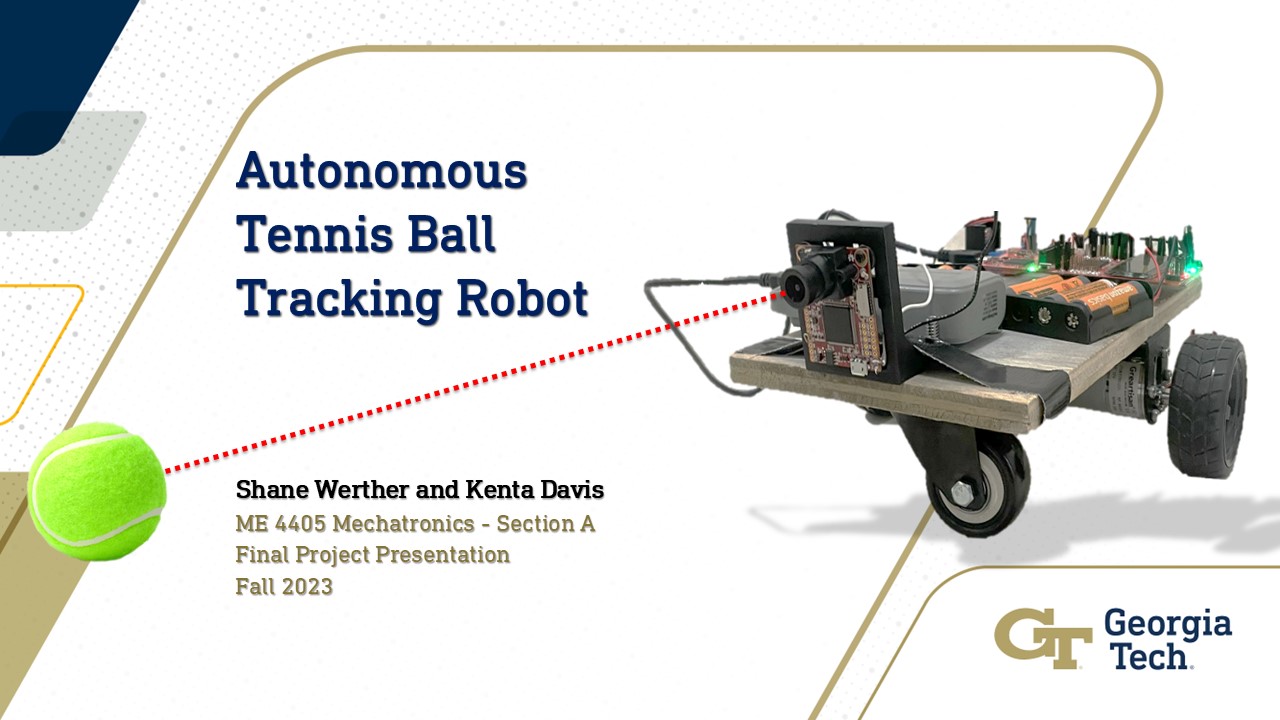
To complete my mechatronics project at the end of the year, my group mate and built a tennis ball following robot.
The thought behind the project was to create something that utilizes a lot of what was learned in the class and yet simple enough to complete entirely within 2 weeks.
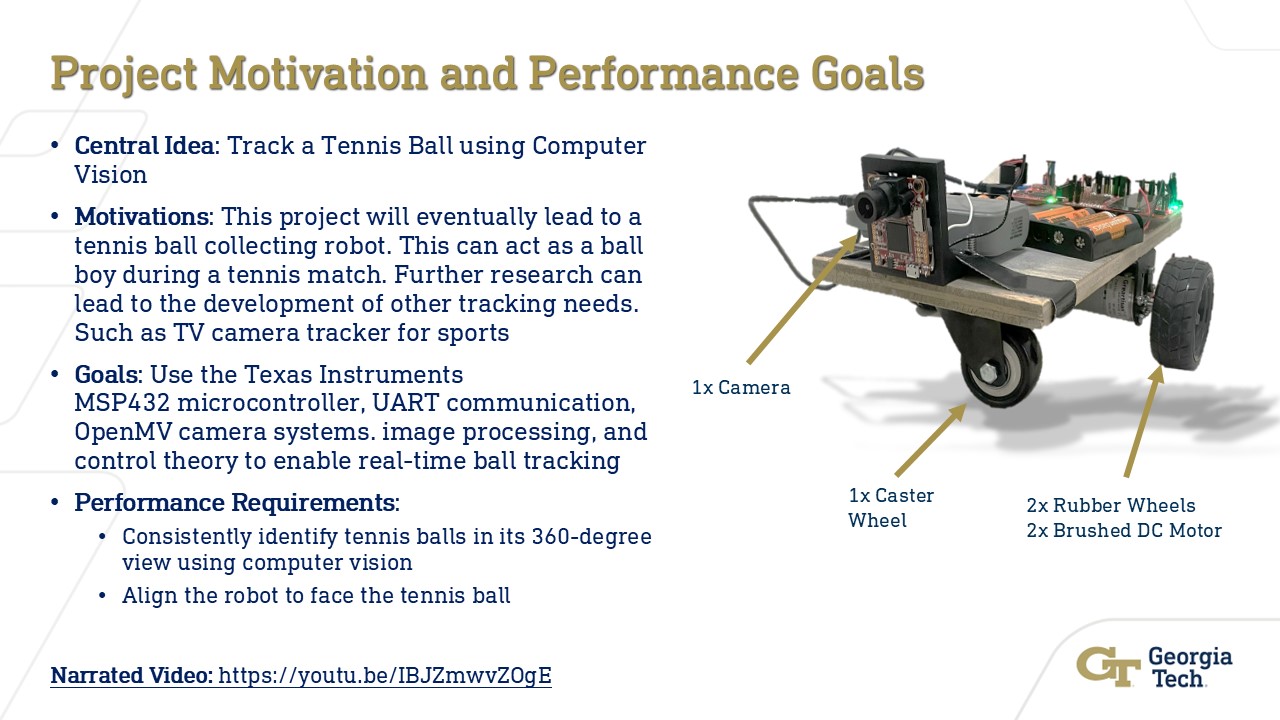
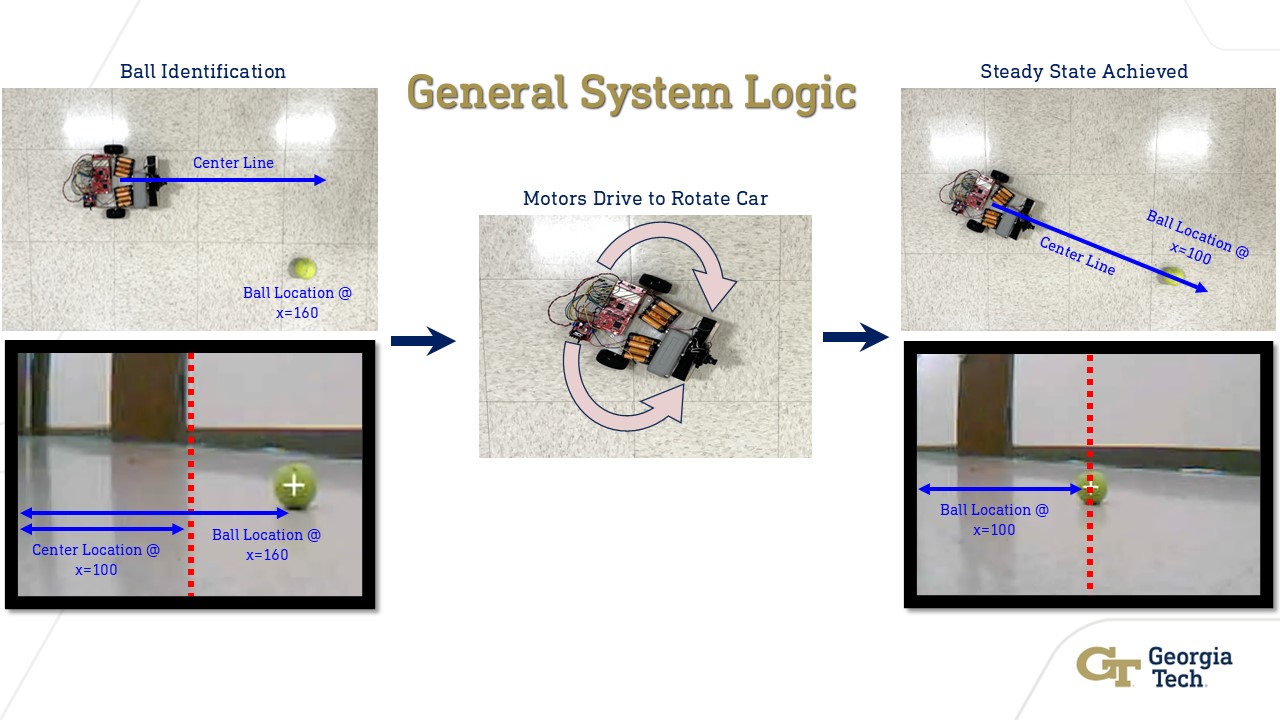
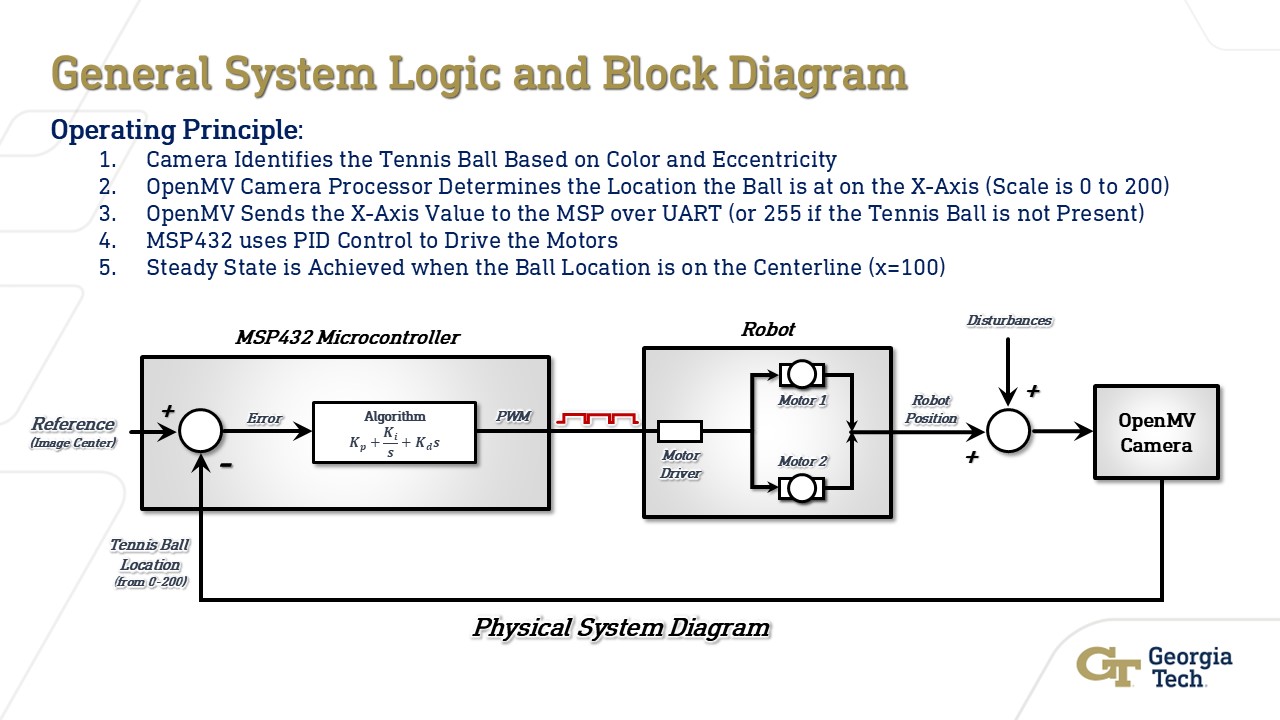
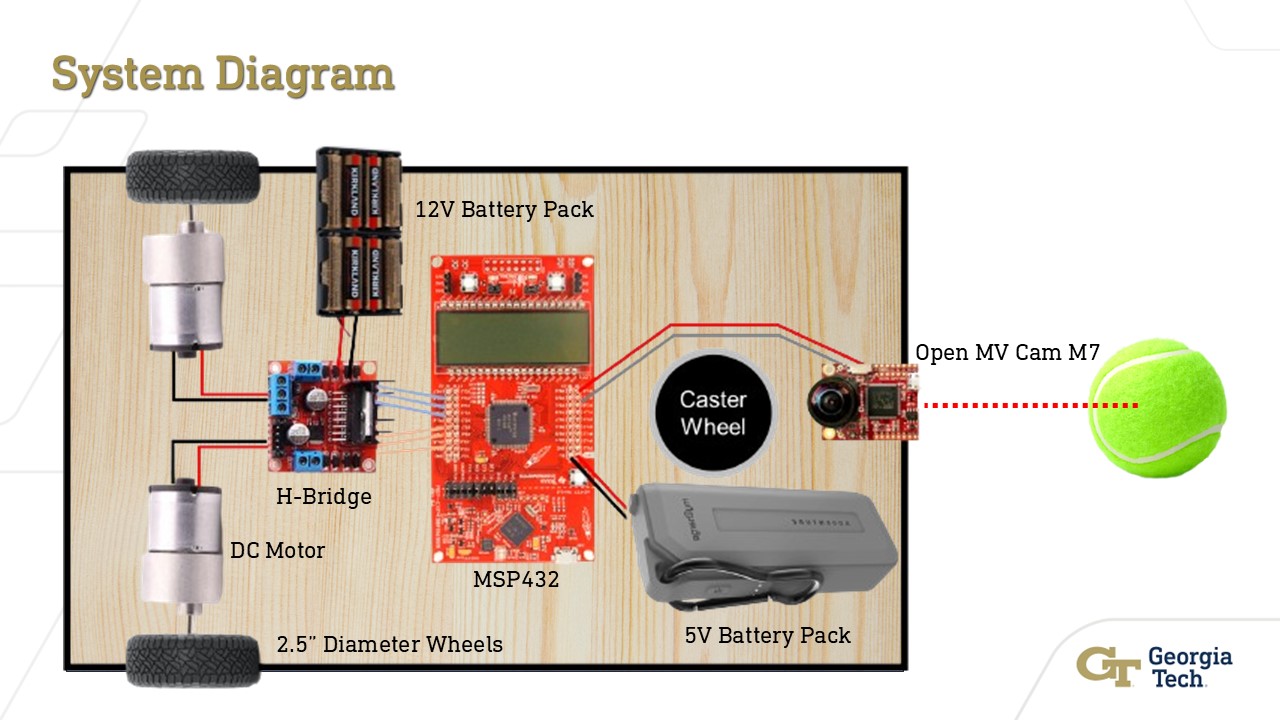
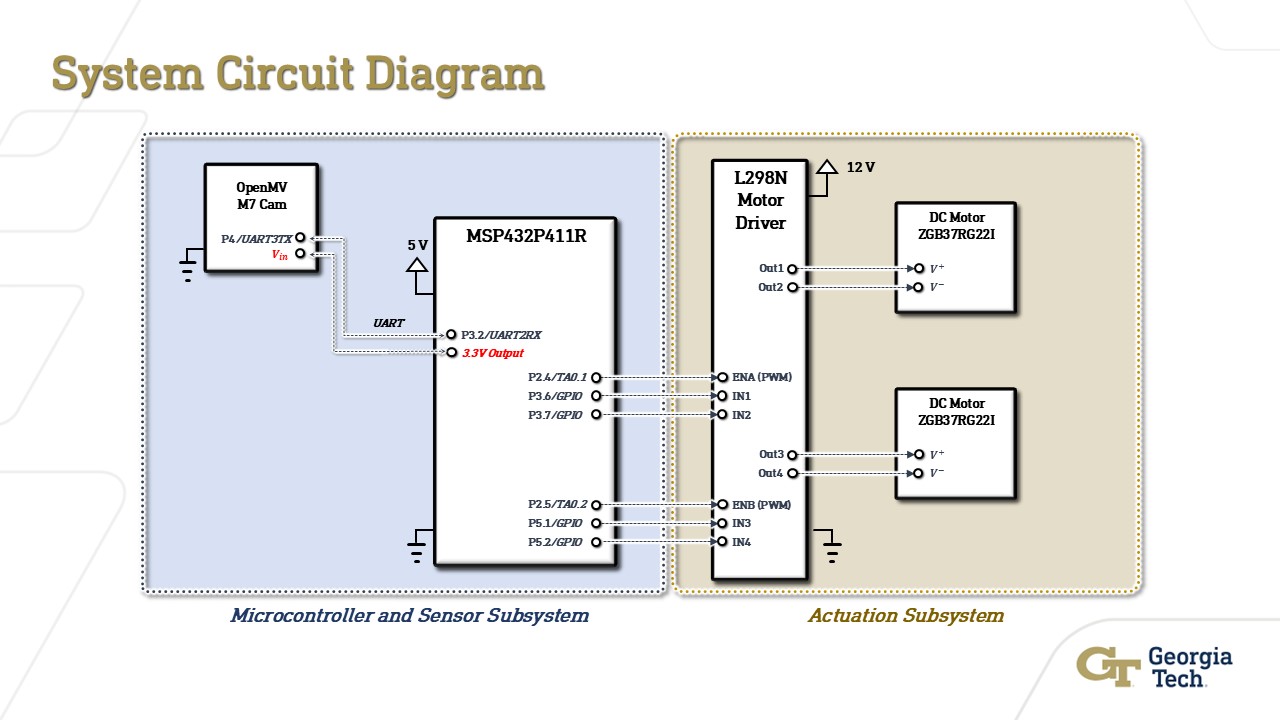
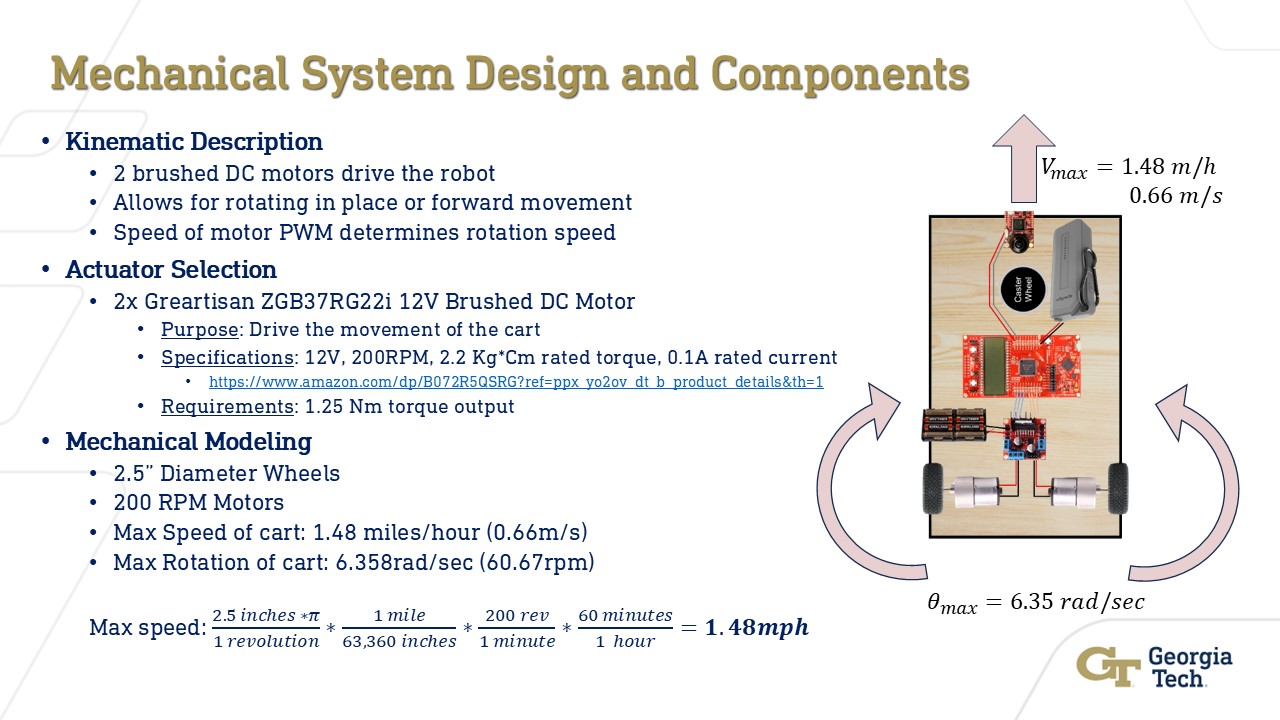
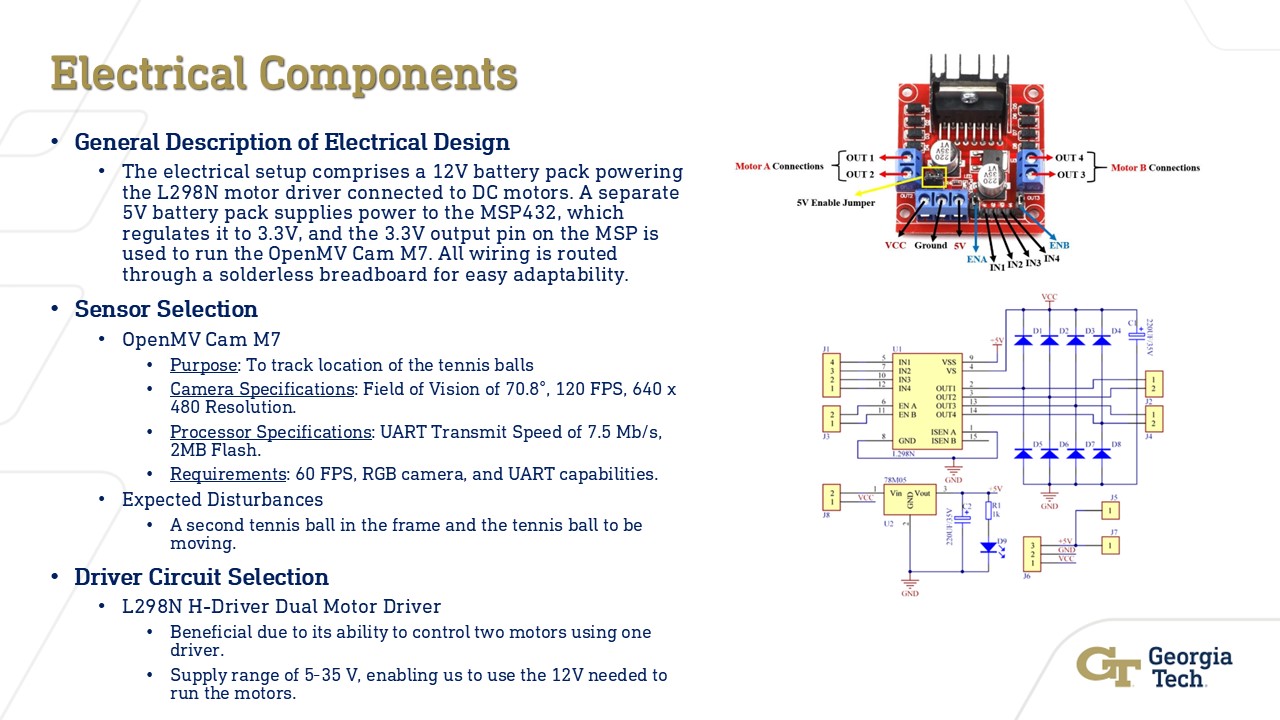
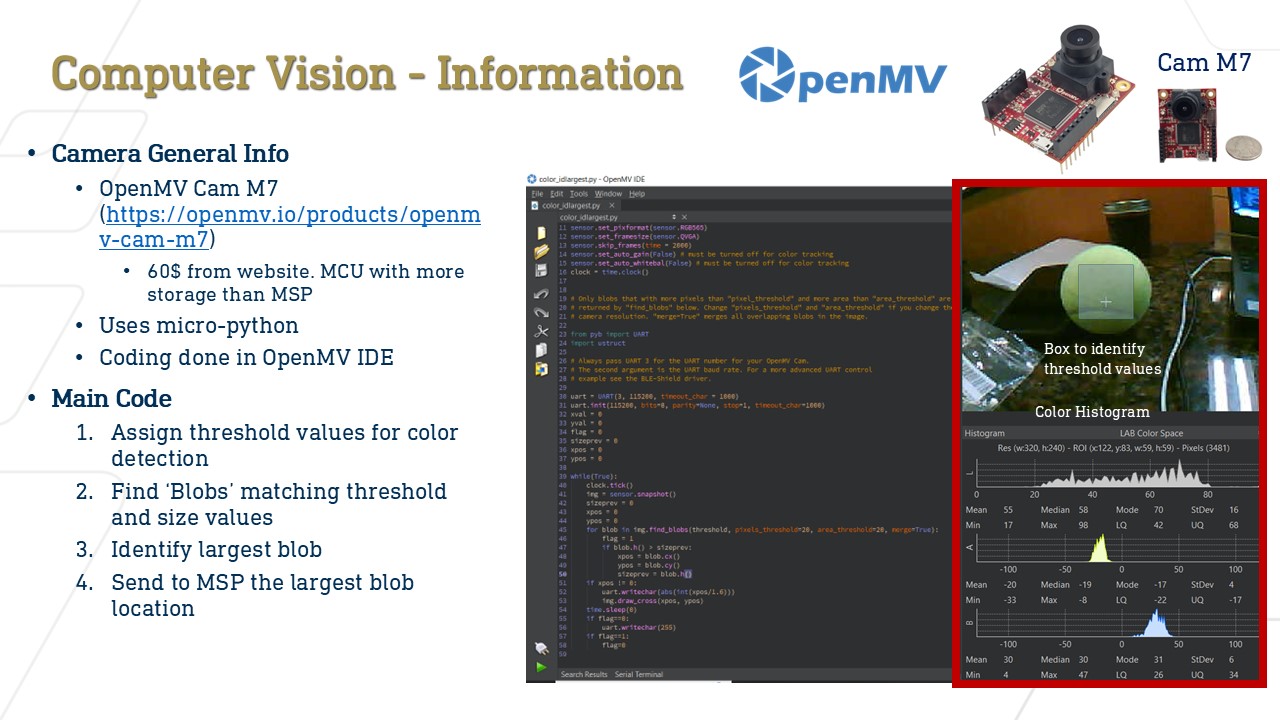
The project uses the Texas Instruments MSP432 which receives data from a Open MV M7 Camera over UART protocol. Using this information, the MSP432 commands the motors to drive.
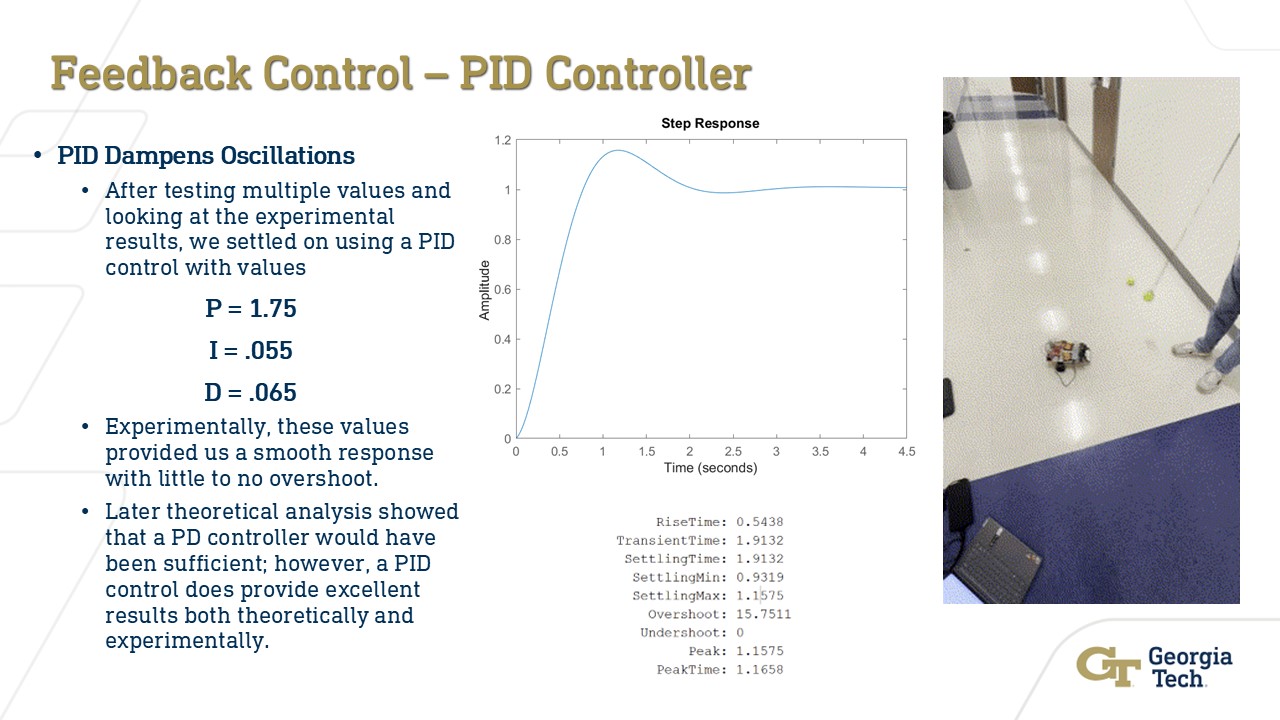
The robot worked amazingly well, and could very quickly identify the yellow shape, rotate to point towards the ball, and move forward to the ball. Even upon rolling the ball down the hallway, the robot would successfully chase it, sometimes reaching the ball before I could reach it.
 Return to main